Highlighted Project Works
Robotics & Autonomous Systems
Jenga-Playing Robotic Arm
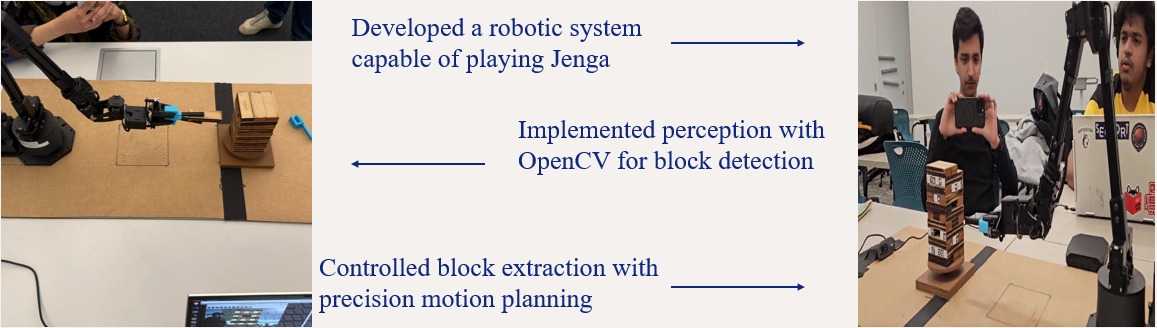
Developed an autonomous robotic manipulation system that integrates computer vision and motion planning to interact with a Jenga tower.
Key components:
- Implemented an OpenCV-based vision pipeline to detect, segment, and localize individual Jenga blocks.
- Designed motion planning strategies to identify stable blocks and perform controlled extraction without destabilizing the tower.
- Integrated perception and manipulation with the robotic arm to achieve reliable block interaction and placement.
Project Repository:
Autonomous Mobile Robot
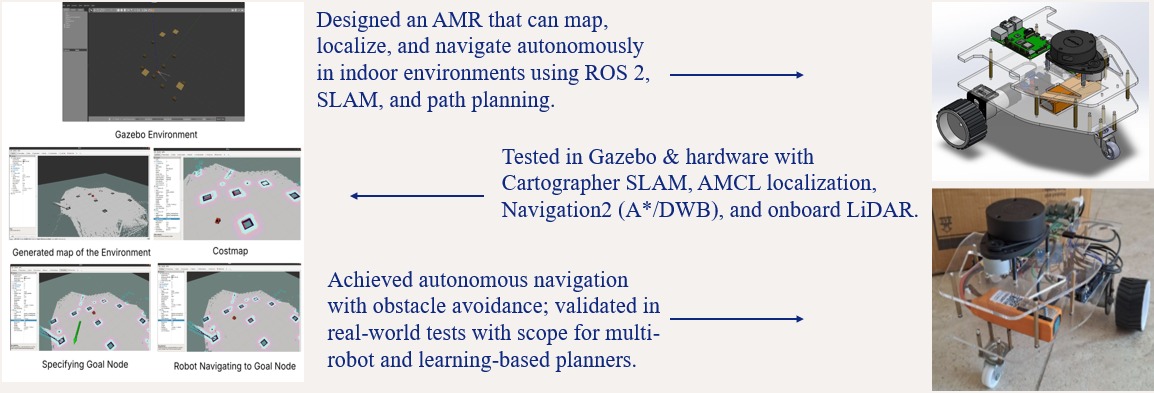
Designed and implemented an Autonomous Mobile Robot (AMR) capable of mapping, localization, and navigation in indoor environments using the ROS 2 framework.
Key components:
- Built a ROS 2-based mobile robotics stack integrating Cartographer SLAM for map generation and AMCL for probabilistic localization.
- Configured the Navigation2 framework with global and local planners (A* / DWB) to enable goal-driven navigation with dynamic obstacle avoidance.
- Validated the system both in Gazebo simulation and real hardware, integrating onboard LiDAR sensing for mapping and perception.
Project Repository:
APG-RRT Path Planner in ROS2
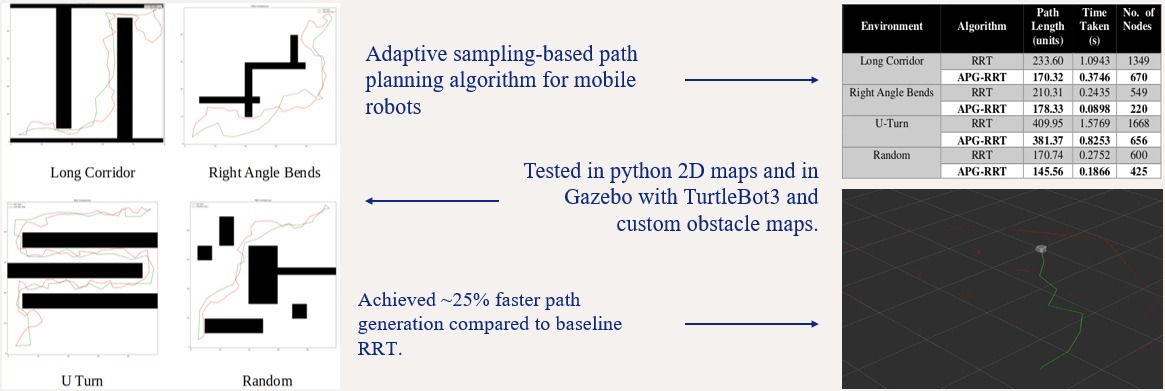
Implemented an Adaptive Path-Guided Rapidly-Exploring Random Tree (APG-RRT) planner for mobile robot navigation and evaluated its performance against the standard RRT algorithm.
Key components:
- Adaptive sampling-based path planning algorithm.
- Evaluated planner performance across multiple 2D benchmark environments including long corridors, right-angle bends, and cluttered obstacle maps.
- Integrated the planner with TurtleBot3 in Gazebo using custom occupancy maps for navigation testing.
- Demonstrated ~25% reduction in path generation time compared to baseline RRT while maintaining feasible navigation paths.
Project Repository:
Three-Link Planar Biped Walking using Hybrid Zero Dynamics and Nonlinear Control
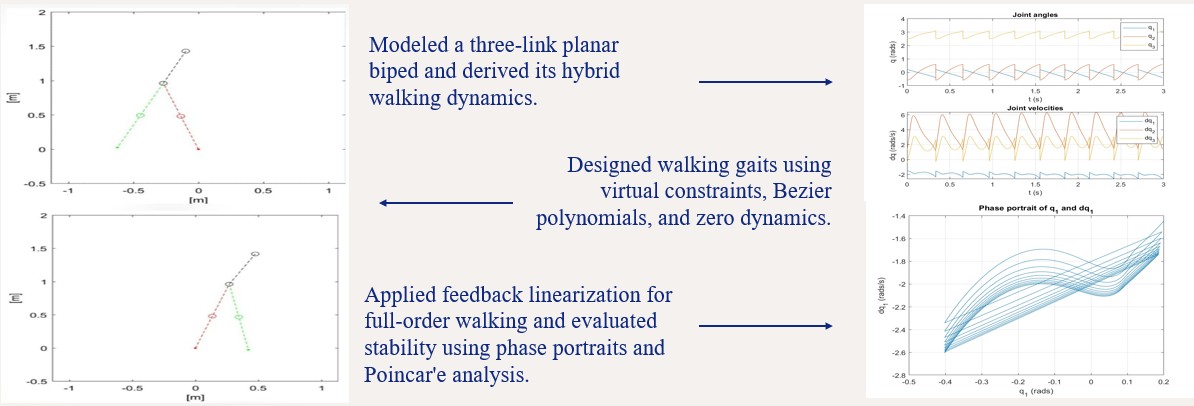
Designed and implemented a three-link planar biped to study gait generation and closed-loop walking using hybrid dynamics and nonlinear control.
Key components:
- Derived the robot dynamics using the Lagrangian formulation and expressed them in manipulator form.
- Used Hybrid Zero Dynamics (HZD) for stable reduced-order walking gaits.
- Designed Bezier polynomial-based virtual constraints for joint trajectories.
- Optimized gait parameters using numerical optimization techniques (MATLAB’s fmincon).
- Simulated walking behavior and analyzed stability using phase portraits and Poincaré maps.
Project Repository:
Perception, Computer Vision & Localization
Structure-from-Motion (SfM) 3D Reconstruction
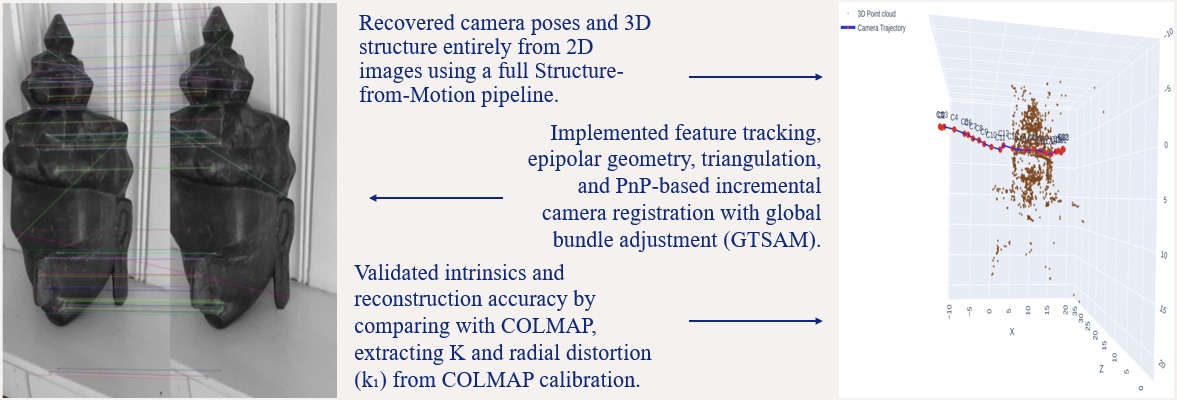
Implemented a complete Structure-from-Motion (SfM) pipeline to recover camera poses and reconstruct 3D scene geometry from multiple 2D images.
Key components:
- Extracted and matched visual features to establish multi-view correspondences across image pairs.
- Estimated relative camera motion using epipolar geometry and incremental PnP-based pose estimation.
- Generated 3D landmarks through triangulation and incremental reconstruction as additional views were registered.
- Performed global bundle adjustment using GTSAM to jointly optimize camera poses and 3D point estimates.
- Evaluated reconstruction accuracy by comparing intrinsic parameters and results against COLMAP calibration outputs.
Project Repository:
Camera–LiDAR Extrinsic Calibration (On-the-Fly)
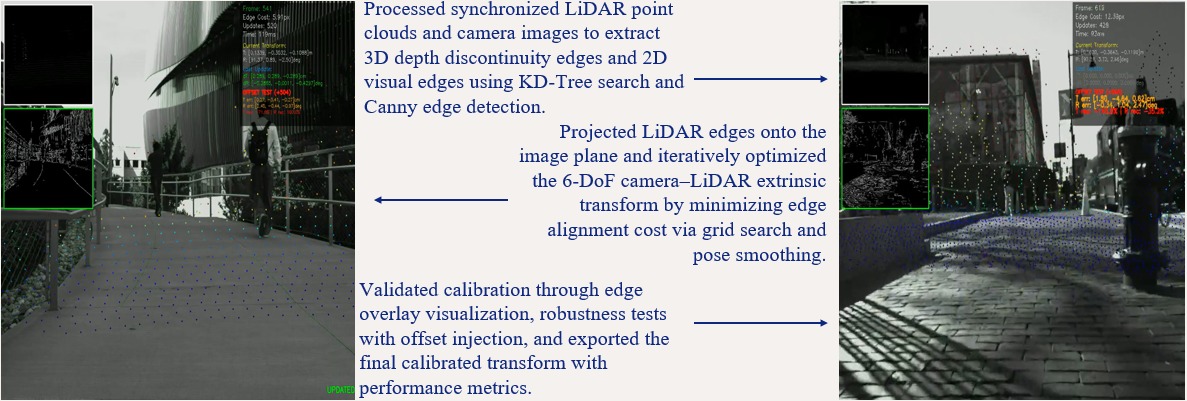
Developed a pipeline to estimate the 6-DoF extrinsic transformation between camera and LiDAR sensors during runtime using geometric feature alignment.
Key components:
- Processed synchronized LiDAR point clouds and camera images to extract depth discontinuities and visual edge features.
- Identified corresponding geometric structures using KD-Tree search and Canny edge detection.
- Optimized the camera-LiDAR transform using grid search and pose refinement.
- Validated calibration quality through edge overlay visualization, robustness tests with injected offsets, and quantitative alignment metrics.
Project Repository:
Panoramic Image Stitching for Low-Contrast Images
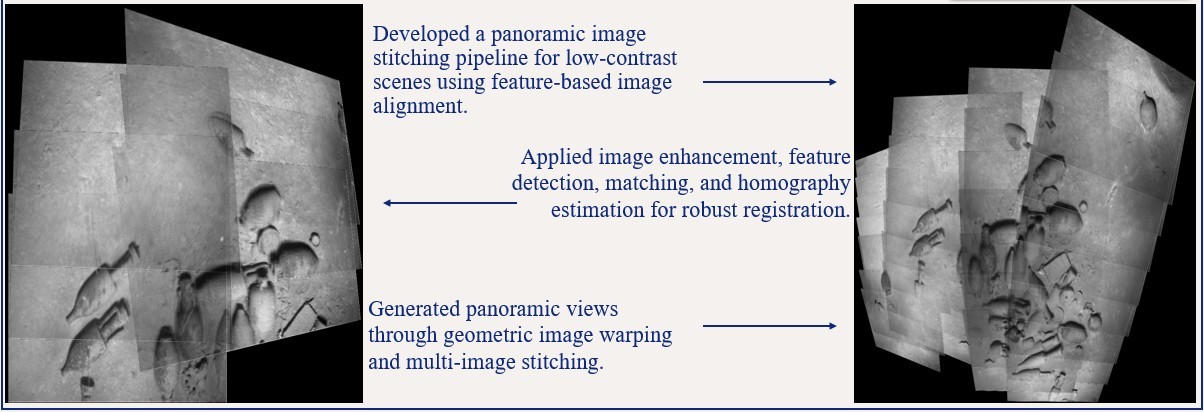
Developed a computer vision pipeline for panoramic image generation from low-contrast image sequences using feature-based image alignment and stitching techniques.
Key components:
- Enhanced low-contrast images through preprocessing and contrast adjustment techniques.
- Detected and matched visual features across overlapping images.
- Estimated image transformations using homography and geometric alignment methods.
- Generated panoramic views through image warping and stitching.
Project Repository:
Related Work: Implemented a similar panoramic image stitching pipeline for high-contrast image datasets.
AI - RL, ML, Neural Networks
Robotic Manipulation using SmolVLA (Physical AI Hackathon)
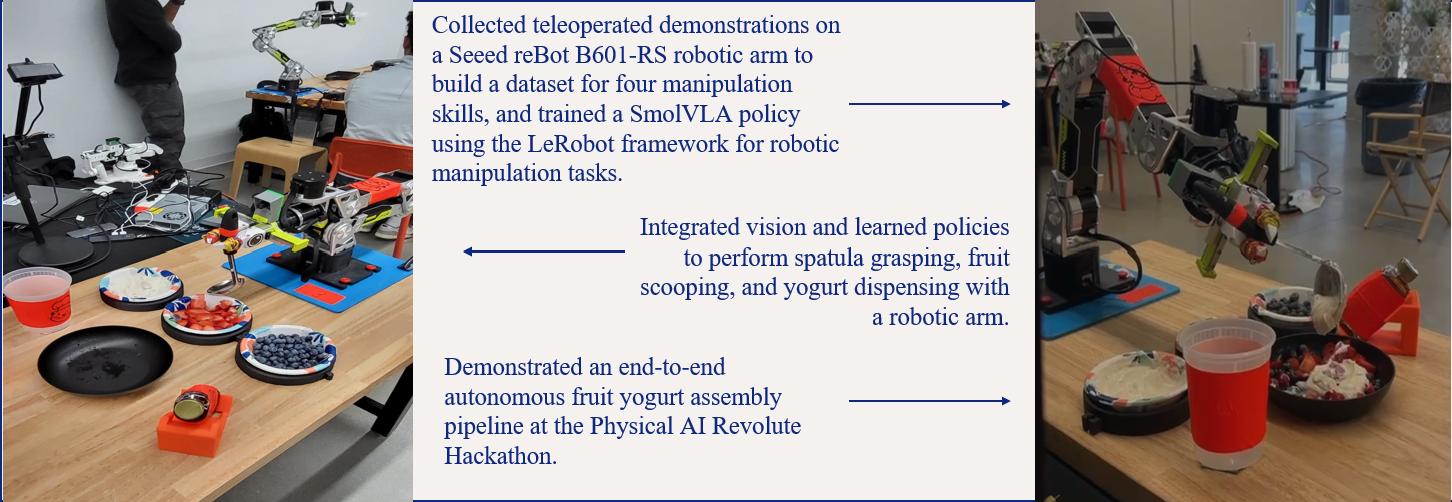
Developed a learning-based robotic manipulation pipeline using LeRobot and SmolVLA to enable autonomous food assembly with a Seeed reBot B601-RS robotic arm.
Key components:
- Collected teleoperated demonstrations to build a dataset for four manipulation skills including spatula grasping, fruit scooping, and yogurt dispensing.
- Trained and deployed a SmolVLA policy using the LeRobot framework for vision-based robotic manipulation.
- Integrated learned policies with robot perception to perform an end-to-end autonomous fruit yogurt assembly task.
- Demonstrated the complete manipulation pipeline at the Physical AI Revolute Hackathon, August 2026.
Project Repository:
Robotic Manipulation using SmolVLA
POMDP Navigation in MiniGrid
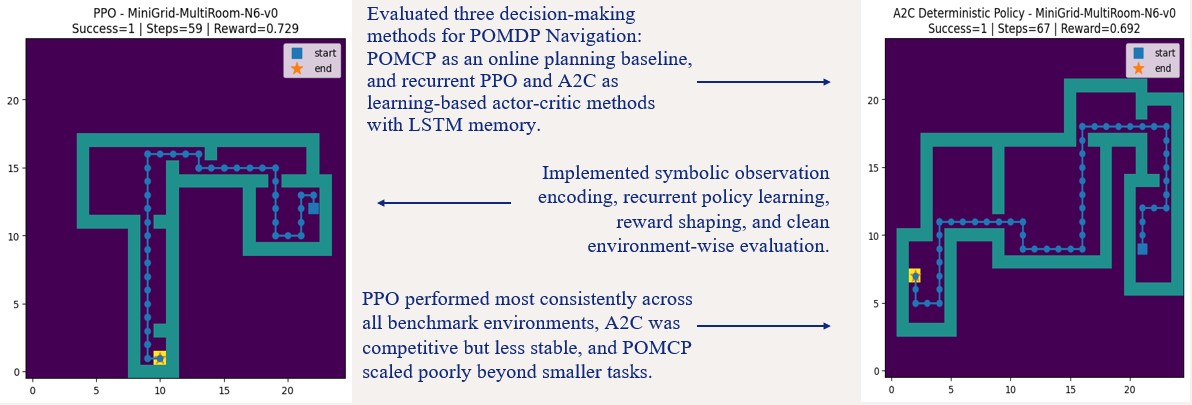
Implemented a navigation pipeline for partially observable MiniGrid tasks using reinforcement learning methods.
Key components:
- Formulated navigation as a Partially Observable Markov Decision Process (POMDP).
- Implemented and compared POMCP, PPO, and A2C agents.
- Designed observation encoding and history-based representations for partial observability.
- Applied reward shaping and exploration strategies to improve learning efficiency.
- Evaluated performance across multiple environments with increasing complexity and stochasticity.
Project Repository:
Parkinson’s Disease Classification using Machine Learning
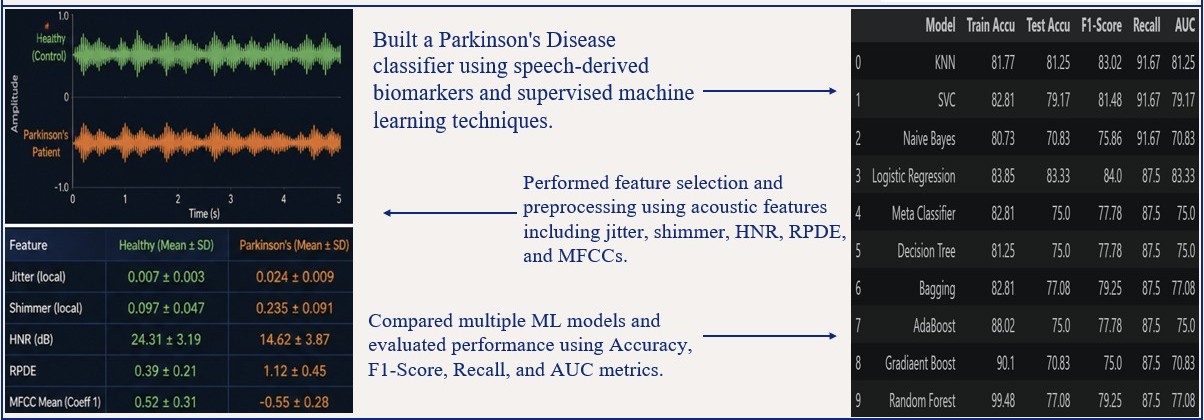
Developed a Parkinson’s Disease classification pipeline using speech-derived biomarkers and supervised machine learning techniques.
Key components:
- Applied feature selection and preprocessing using acoustic speech features including jitter, shimmer, HNR, RPDE, and MFCCs.
- Trained and evaluated multiple machine learning models including KNN, SVM, Naive Bayes, Logistic Regression, Random Forest, AdaBoost, and Gradient Boosting.
- Compared model performance using Accuracy, Recall, F1-Score, and AUC metrics.
Project Repository:
Parkinson’s Disease Classification
Fault Diagnosis of IC Engine Gearbox using Voting Classifiers
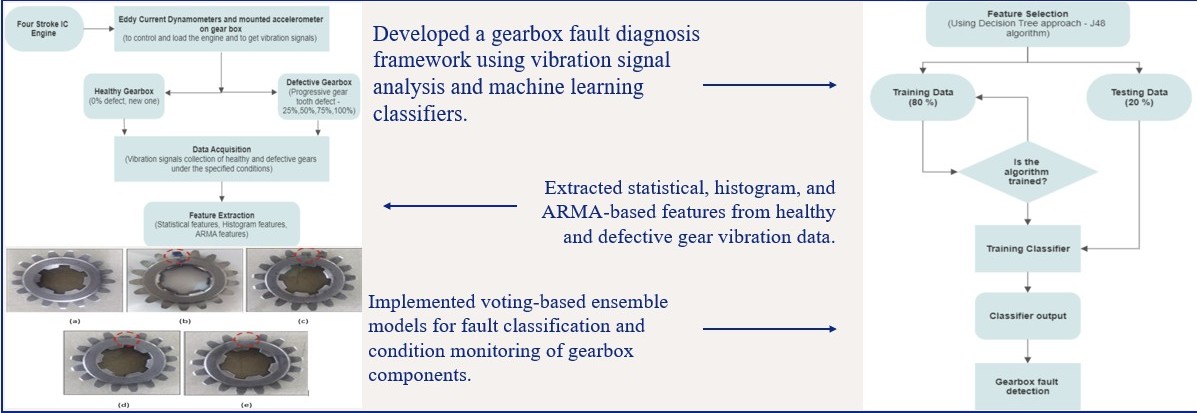
Developed a machine learning framework for gearbox fault diagnosis using vibration signal analysis and ensemble voting classifiers.
Key components:
- Collected vibration data from healthy and defective gearbox systems under controlled operating conditions.
- Extracted statistical, histogram, and ARMA-based features from vibration signals.
- Implemented voting-based ensemble classifiers for automated fault detection and condition monitoring.
Project Repository:
Clutch Fault Diagnosis using WiSARD Classifier
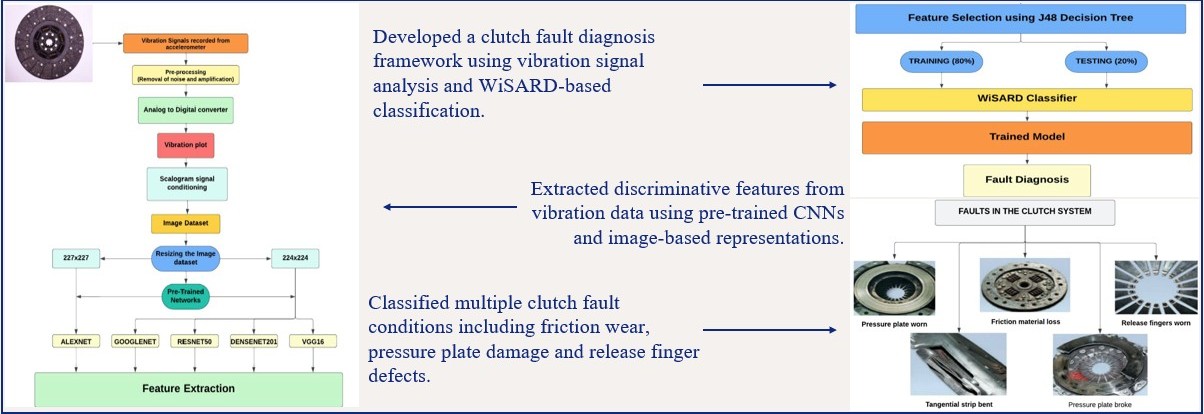
Developed a clutch fault diagnosis framework using vibration signal processing, deep feature extraction, and WiSARD-based classification.
Key components:
- Converted vibration signals into image representations for machine learning analysis.
- Extracted discriminative features using pre-trained convolutional neural networks.
- Implemented a WiSARD classifier to identify multiple clutch fault conditions and component failures.
Project Repository: