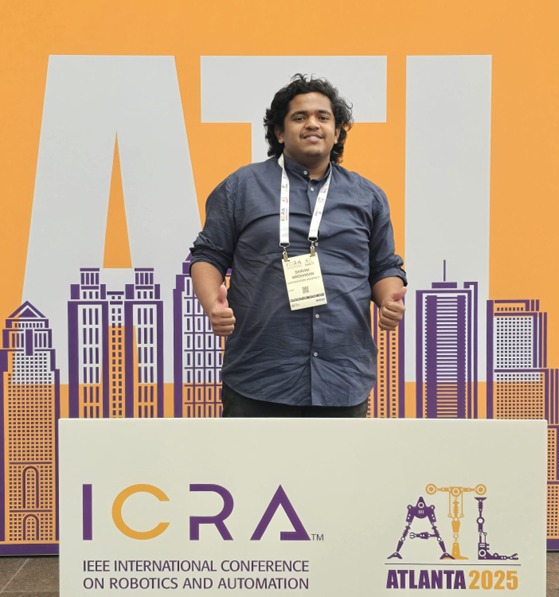
Hi, I'm Sairam Sridharan, a robotics engineer with a Master's degree in Robotics from Northeastern University and a Bachelor's degree in Mechatronics and Automation from Vellore Institute of Technology. I'm passionate about building intelligent robotic systems and solving challenging problems involving perception, planning, control, and learning. With a strong analytical mindset and technical knowledge, I enjoy solving challenging engineering problems and translating ideas into robotic solutions.
My work focuses on developing robotic systems across autonomous navigation, robot simulation, manipulation, and machine learning. Areas of experience include sensor fusion, SLAM, motion planning, optimization, computer vision, deep learning, reinforcement learning, and robot control.
My experience spans both the software and mechanical sides of robotics, from CAD and prototyping to perception, learning, control, and navigation algorithms. Although my interests are primarily focused on autonomy and software development, I believe the most effective robotic systems are built through the integration of hardware and software. I like working across the full robotics stack and solving system-level challenges.
Programming:
Software & Tools:
Robotics & AI:
Autonomous navigation, Robot perception and control, Motion planning, Sensor fusion, Computer vision, Legged locomotion, Reinforcement learning, Deep Learning, Industrial automation, and Robot design and development.